Self-Balancing Robot
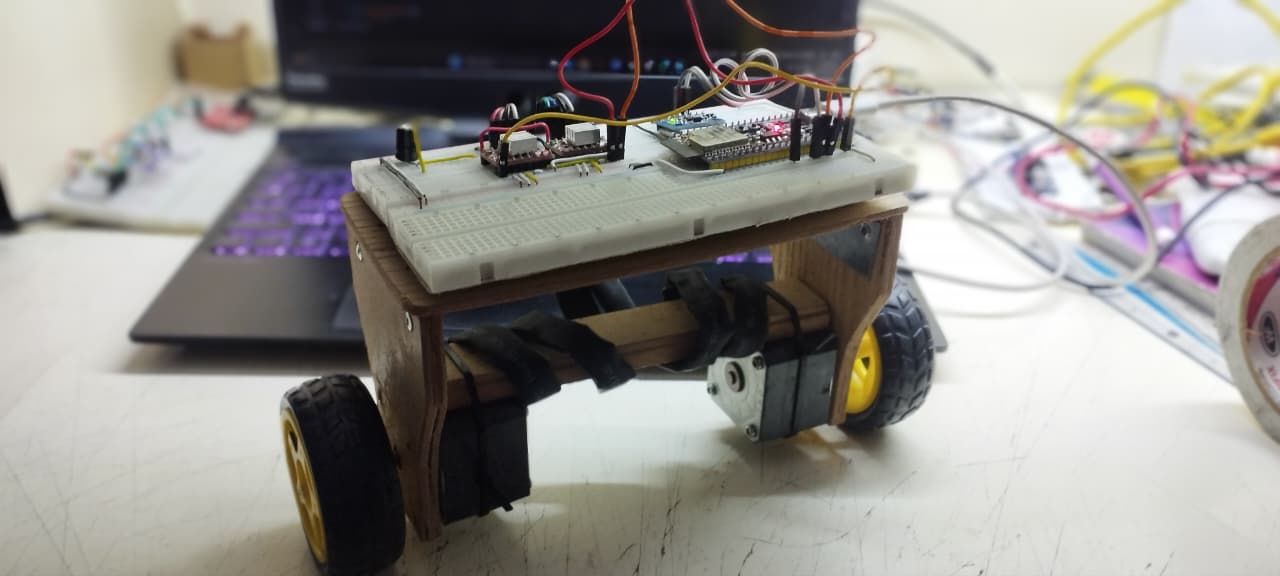
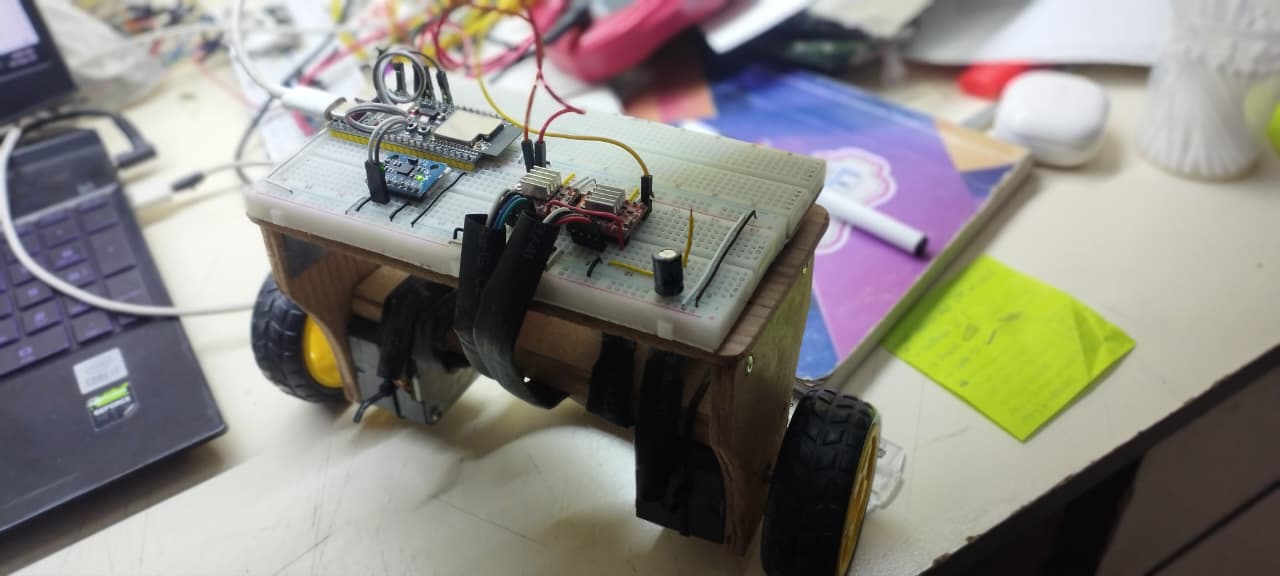
A two-wheeled self-balancing robot built from scratch, first on Arduino Nano and then rebuilt on ESP32.
- Designed and built a two-wheeled self-balancing robot from scratch (wooden chassis, wiring, control system). Initially developed on Arduino Nano, then recreated on ESP32 to challenge myself with a different platform.
- Developed a custom MPU6050 library based on the datasheet and register map.
- Implemented low-pass and complementary filters for IMU readings, and applied PID control tuned via trial-and-error to maintain stability.
- Written up as a paper with Muhammad Aqdas Chaudhary and Murtaza Ahmed Khan (NUST).
Next project: 3-DoF Robotic Arm